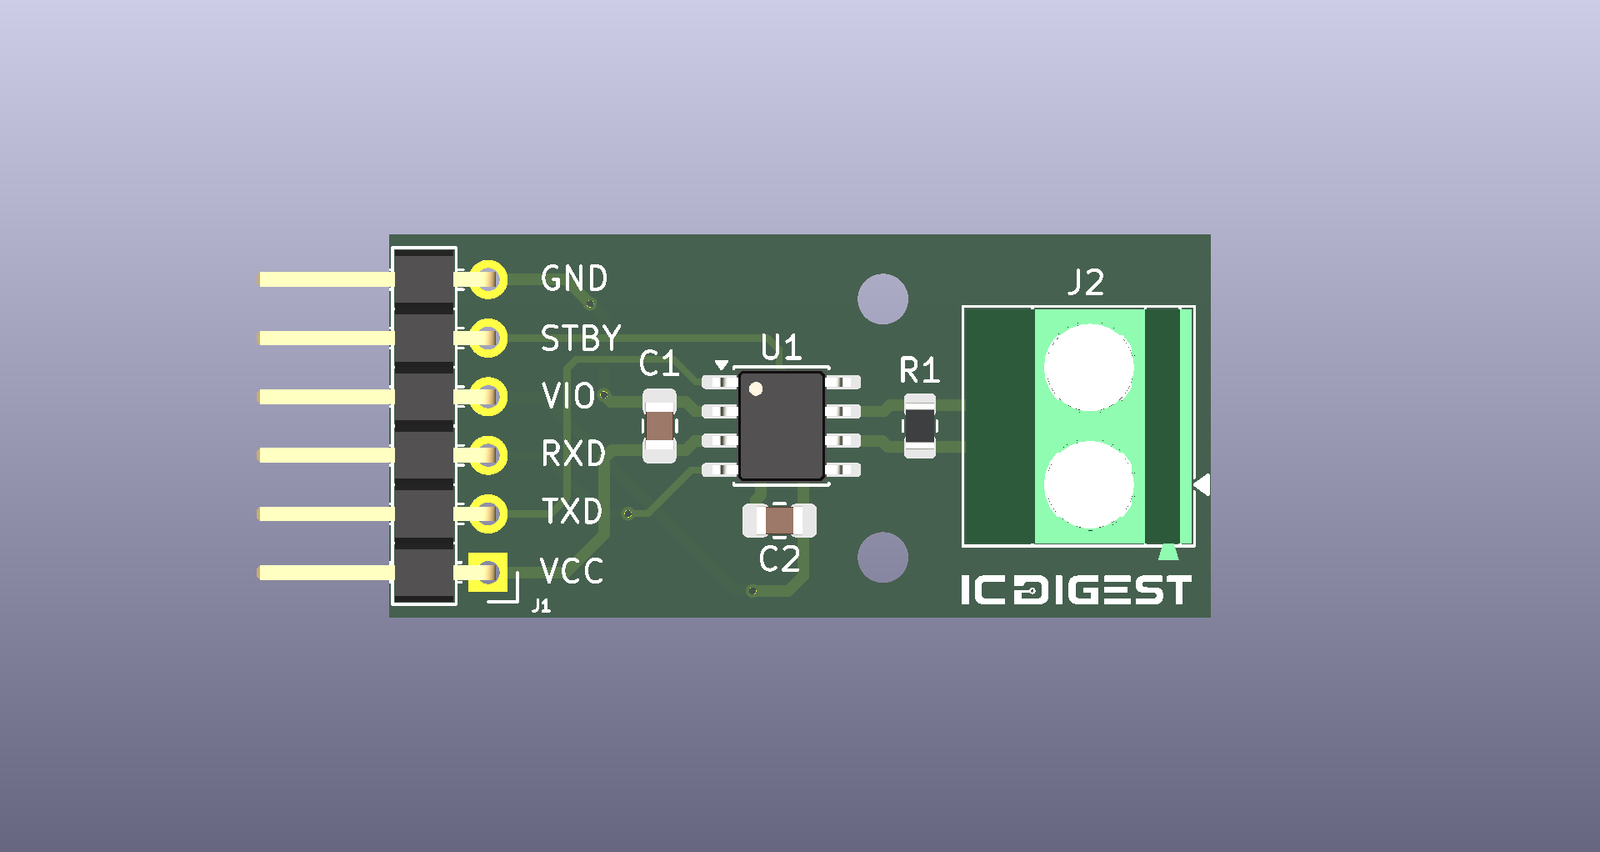
Information Header
| Field | Value |
| Design Block ID | DB-0001 |
| Design Block Name | CAN Bus Interface using MCP2562 |
| Category | Communication |
| Sub Category | CAN Bus |
| Primary IC | MCP2562 |
| Manufacturer | Microchip Technology |
| Protocol | CAN 2.0A / CAN 2.0B |
| Difficulty | Intermediate |
| Version | 1.0 |
| License | CERN-OHL-S v2 |
Quick Summary
The CAN Bus Interface using MCP2562 Design Block provides a complete hardware interface between a CAN controller and a high-speed CAN bus using the Microchip MCP2562 CAN transceiver. It is intended for commercial, industrial, automotive, robotics, and embedded applications requiring reliable differential CAN communication. The design includes all essential supporting circuitry required for stable operation and serves as a reusable hardware building block for professional PCB designs.
Overview
The MCP2562 is a high-speed CAN transceiver compliant with the ISO 11898-2 standard. It converts the single-ended transmit (TXD) and receive (RXD) signals from a CAN controller into differential CANH and CANL bus signals while providing protection against bus faults and electrical disturbances.
This Design Block focuses on the physical layer implementation of the CAN interface. It does not include the CAN controller, which is typically integrated within a microcontroller. The design is suitable for integration into embedded systems where robust communication, noise immunity, and reliable operation are required.
Block Diagram
🔧
Need a modification?
Need changes in this design for your application?
🛠️
Need a new design?
Need changes in this design for your application?
Applications
- Industrial Automation
- Programmable Logic Controllers (PLCs)
- Human Machine Interfaces (HMIs)
- Battery Management Systems (BMS)
- Electric Vehicle (EV) Controllers
- Motor Controllers
- Automotive Electronic Control Units (ECUs)
- Robotics
- Smart Energy Meters
- Solar Inverters
- Building Automation
- Agricultural Equipment
- Data Acquisition Systems
- Embedded Control Systems
Hardware Specifications
| Parameter | Specification |
| Primary IC | MCP2562 |
| Communication Standard | ISO 11898-2 |
| CAN Version | CAN 2.0A / CAN 2.0B |
| Maximum Data Rate | 1 Mbps |
| Supply Voltage (VDD) | 4.5 V to 5.5 V |
| Logic Supply (VIO) | 1.8 V to 5.5 V |
| Bus Interface | Differential (CANH/CANL) |
| Standby Mode | Supported |
| Operating Temperature | Device variant dependent |
| Isolation | No |
Complete BOM
| Ref | Component | Recommended Part | Value / Rating | Package | Manufacturer |
| U1 | CAN Transceiver | MCP2562-E/SN | — | SOIC-8 | Microchip |
| C1 | Decoupling Capacitor | GRM188R71H104KA93 | 100 nF, X7R, 50 V | 0603 | Murata |
| C2 | Bulk Capacitor | GRM188R60J105KA01 | 1 µF, X5R, 6.3 V | 0603 | Murata |
| FB1 | Ferrite Bead | BLM18AG601SN1D | 600 Ω @100 MHz | 0603 | Murata |
| D1 | CAN TVS Diode | SM24CANB | CAN Bus TVS | SMB | Littelfuse |
| L1 | Common Mode Choke | ACT45B-510-2P | CAN Choke | SMD | TDK |
| R1 | Termination Resistor | CRCW0603120RFKEA | 120 Ω, 1%, 0.1 W | 0603 | Vishay |
| JP1 | Termination Jumper | Solder Jumper | — | PCB | — |
| J1 | CAN Connector | 3-Pin Terminal Block | 3.5 mm Pitch | TH | Phoenix Contact |
Equivalent ICs
| IC | Manufacturer | Notes |
| MCP2561 | Microchip Technology | Same application circuit for most designs |
FAQ
1. Does the MCP2562 include a CAN controller?
No. The MCP2562 is only a CAN transceiver. A separate CAN controller, usually integrated into the microcontroller, is required.
2. Can this Design Block be used with a 3.3 V microcontroller?
Yes. The VIO pin supports logic levels from 1.8 V to 5.5 V, allowing direct connection to most modern microcontrollers.
3. Is the 120 Ω termination resistor always required?
No. It should only be installed if the node is located at one end of the CAN bus.
4. Is the common-mode choke mandatory?
No. It is recommended for applications requiring improved EMC performance but may be omitted in less demanding environments.
5. Can this Design Block be used for CAN FD?
No. For CAN FD applications, use a CAN FD transceiver such as the MCP2562FD.
Schematic in pdf
KiCad File